Нет товаров
 Facebook
 Google
- Напишите свой отзыв
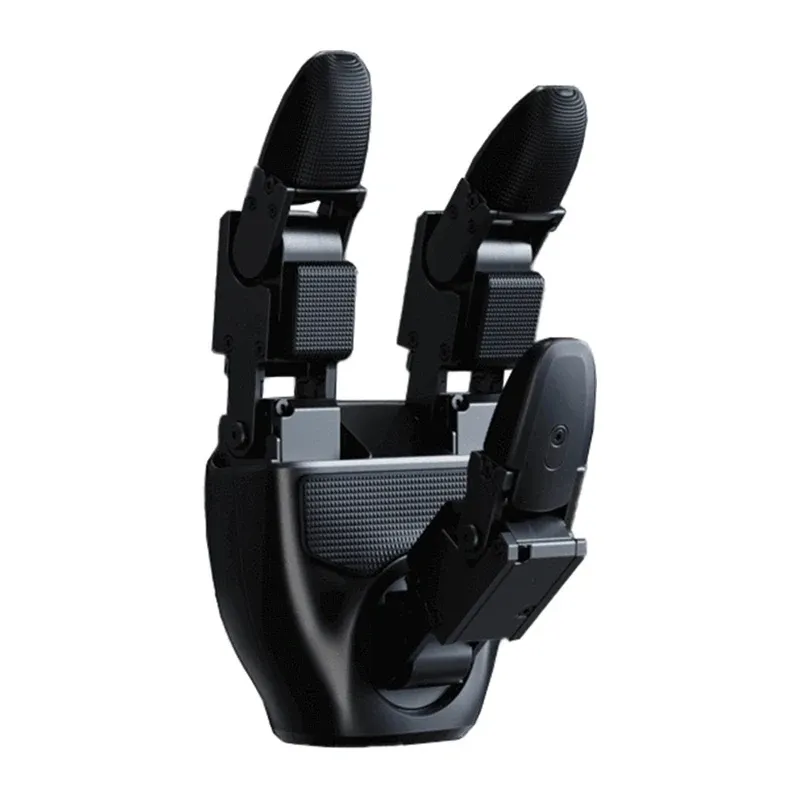
Robotic Hands UNITREE G1 Dex3-1 L+R without tactile sensors


 Помощник на основе искусственного интеллекта
или спросите
| Вид продукта | Другие аксессуары |
| Совместимость | UNITREE G1 |
- 1. Оцените свои возможности.
- 2a. Если вы хотите приобрести только один товар в лизинг через Aizdevums.lv, заполните заявку здесь
- 2b. Если вы хотите приобрести несколько товаров или воспользоваться услугами другой лизинговой компании, добавьте товары в корзину и выберите лизинговую услугу при оформлении заказа.
Мы предлагаем лизинг от Aizdevums SIA, Incredit SIA, ESTO.
Консультанты проверят наличие товаров в корзине и отправят ссылку на заявку на кредит. - 3. Если вы получите положительный ответ, свяжитесь с нами по поводу приобретения товара. Наши консультанты проверят наличие товара.
- 4. Если товар есть в наличии в магазине или его можно заказать со склада, и вы получили положительный ответ от наших консультантов, посетите наш магазин для оформления документов на покупку и аренду.
- 4a. Вы также можете попросить нас выставить счет за этот товар и обратиться в один из филиалов арендодателя для оформления лизинговых документов*.
- 5. После оформления лизинговых документов вы можете забрать товар в магазине (если он есть в наличии) или сообщить нашим консультантам о необходимости заказать его со склада.
- * Возможна организация доставки товаров, приобретенных в лизинг, поэтому весь процесс покупки можно завершить удаленно.
** Та же последовательность действий при заключении договора аренды используется и для договоров аренды, предлагаемых компанией InCredit Group.
*** В случае возникновения каких-либо сомнений, свяжитесь с нашими консультантами!
Внимание! При использовании лизинговых услуг тщательно оцените свою платежеспособность!Отправить заявку
UNITREE G1 Dex3-1 robotic hands (left + right) without tactile sensors
The UNITREE G1 Dex3-1 set includes a left and right three-fingered robotic hand designed to work with the UNITREE G1 humanoid robot. Each hand offers 7 degrees of freedom and utilizes 7 miniature brushless joints with force control. Hybrid force and position control allows for precise movement control, and the positioning repeatability of the fingertip is ±2 mm. Communication at a frequency of 1,000 Hz, a USB 2.0 interface, and a wide range of feedback data enable complex manipulations and precise control of the mechanism’s operation.

7 degrees of freedom for precise movement
Each Dex3-1 hand has three movable fingers—the thumb has 3 degrees of freedom, the index finger has 2, and the middle finger has another 2. The range of motion of each joint allows for complex grip configurations—for the thumb, it ranges from -60° to 60°, from -35° to 60°, and from 0° to 100°, while the joints of the index and middle fingers operate within ranges of 0° to 90° and 0° to 100°, respectively. This design allows the fingers to be repositioned in multiple planes and their arrangement to be adjusted to the task at hand. The positioning repeatability of the fingertip at ±2 mm further supports tasks requiring consistent movement reproduction.

Hybrid Force Control and Advanced Joints
The UNITREE Dex3-1 utilizes hybrid force and position control, meaning control is not limited solely to setting a specific finger position. The design of each hand includes 6 miniature, directly driven brushless force-control joints and 1 joint using a geared drive. The F-1515-108 and F-1515-214 models are used, and the system allows for the control of parameters such as torque, angle, angular velocity, stiffness, and damping. For the F-1515-108, the ideal maximum torque is 0.76 Nm, while the actual torque reaches 0.49 Nm in the direction of rotation and 1.37 Nm in the opposite direction. For the F-1515-214, these values are 1.498 Nm for ideal torque and 0.86 Nm and 3.1 Nm for actual torque, respectively.

Comprehensive Operational Feedback Data
The system provides a wide range of information regarding the current state of the mechanism. Sensing data includes the joint’s mode, position, velocity, torque, and temperature, as well as voltage, current, and IMU data. The control feedback also includes the joint’s stiffness and damping coefficients. This allows for precise monitoring of the hand’s behavior during task execution and the simultaneous use of multiple parameters during motion planning and control.

1000 Hz Communication and USB 2.0
The hand’s communication interface uses USB 2.0, and the communication frequency is 1000 Hz. A full data packet is 1,234 bytes on the transmit side and 1,270 bytes on the receive side. The joint control frequency is also 1,000 Hz, and High Speed Unibus is used for joint communication. These parameters provide access to a large amount of information about the hand’s status and enable frequent updates to control parameters during the execution of complex motion sequences.

Design tailored to the UNITREE G1 robot
A single hand weighs 710 g, and its dimensions when extended are 175 × 88 × 77 mm. Dex3-1 can work in conjunction with the UNITREE G1 humanoid robot and enables the performance of a variety of complex manipulative tasks. The mechanism’s compact dimensions are combined with an advanced motion control system and a feedback system, providing access to a wide range of data regarding the hand’s operation.

General
| Manufacturer | UNITREE |
|---|---|
| Model | DX31-214N |
| Compatibility | UNITREE G1 |
Hand Specifications
| Weight | 710 g |
|---|---|
| Dimensions | 175 × 88 × 77 mm (when extended) |
| Degrees of Freedom | Thumb ×3 Index finger ×2 Middle Finger ×2 |
| Drive Mechanism | 6 direct-drive motors 1 gear-driven motor |
| Joint Range of Motion | Thumb Joint 0: -60° to 60° Thumb joint 1: -35° to 60° Thumb joint 2: 0° to 100° Index finger joint 0: 0° to 90° Index finger joint 1: 0° to 100° Middle finger joint 0: 0° to 90° Middle finger joint 1: 0° to 100° |
| Finger tip positioning repeatability | ±2 mm |
| Operating voltage | 12–58 V |
| Quiescent current | 0.2 A at 58 V |
| Maximum current | 10 A |
| Communication interface | USB 2.0 |
| Operating temperature range | From -20°C to 60°C |
| Load conditions (palm facing down, room temperature, gripping a hard round object with a diameter of 5 cm) | Maximum weight: 500 g Maximum power: 400 W for 3 s |
| Load conditions (palm facing left, room temperature, gripping a hard round object with a diameter of 5 cm) | Maximum weight: 500 g Maximum power: 400 W for 3 s |
Software features
| Communication frequency | 1000 Hz |
|---|---|
| Number of bytes in a full data packet | Transmitter: 1234 bytes Receiver: 1270 bytes |
| Measurement feedback data | Joint mode Joint position Joint speed Joint torque Joint temperature Voltage and current IMU data |
| Control feedback data | Joint mode Joint position Joint speed Joint torque Joint stiffness coefficient Joint damping coefficient |
Parameters of a miniature brushless force-controlled joint
| Model | F-1515-108 Miniature Brushless Force-Controlled Joint F-1515-214 Miniature Brushless Force-Control Joint |
|---|---|
| Weight | 45 g |
| Dimensions | 34.8 × 23.1 × 23.3 mm |
| Gear Ratio | F-1515-108: 1:108 F-1515-214: 1:214 |
| Maximum Torque (theoretical value) | F-1515-108: 0.76 Nm F-1515-214: 1.498 Nm |
| Maximum Torque (actual value, torque in the direction of rotation) | F-1515-108: 0.49 Nm F-1515-214: 0.86 Nm |
| Maximum torque (actual value, torque opposite to the direction of rotation) | F-1515-108: 1.37 Nm F-1515-214: 3.1 Nm |
| Maximum rotational speed | F-1515-108: 23 rad/s F-1515-214: 11 rad/s |
| Maximum line current | 4.76 A |
| Control communication frequency | 1000 Hz |
| Communication method | High Speed Unibus |
| Encoder | Absolute rotor position encoder |
| Operating temperature range | From -20°C to 60°C |
| IP rating | / |
| Operating voltage | 12–24 V |
| Motor feedback | Torque Angle Angular velocity Temperature |
| Motor control commands | Torque Angle Angular velocity Stiffness Damping |