No products
 Facebook
 Google
- Write a review
Robotic Hands UNITREE G1 Dex3-1 L+R with tactile sensor


 AI ASSISTANT CHAT
Or ask about:
| Type of Product | Other Accessories |
| Compatible | UNITREE G1 |
- 1. Evaluate your options.
- 2a. If you want to buy only one product with Aizdevums.lv leasing, then fill out the application here
- 2b. If you want to buy several items or use another leasing company, then put the items in the basket and choose the leasing service when ordering.
We offer leasing from Aizdevums SIA, Incredit SIA, ESTO.
Manager will check the availability of the items in the cart and send the loan application link. - 3. If you receive a positive response, contact us to purchase the product. Consultants will check the availability of the product.
- 4. If the product is available in the store or to be ordered from the warehouse, and you have received an affirmative answer from our consultants, please visit the store to proceed with purchase and leasing documents.
- 4a. You can also ask us to issue an invoice for this product and visit one of the leasing company branches to sign up leasing documents *..
- 5. Once the leasing documents have been signed up, you can receive the product in the store, if it is on site or inform our consultants and they will order it for you from the warehouse.
- *It is possible to arrange delivery for leased goods, so you can also perform the entire purchase process remotely.
**The sequence of leasing steps is the same for leases offered by InCredit Group.
***In case of doubt, contact our consultants!
When using leasing services, carefully evaluate your options to repay the loan!Lease
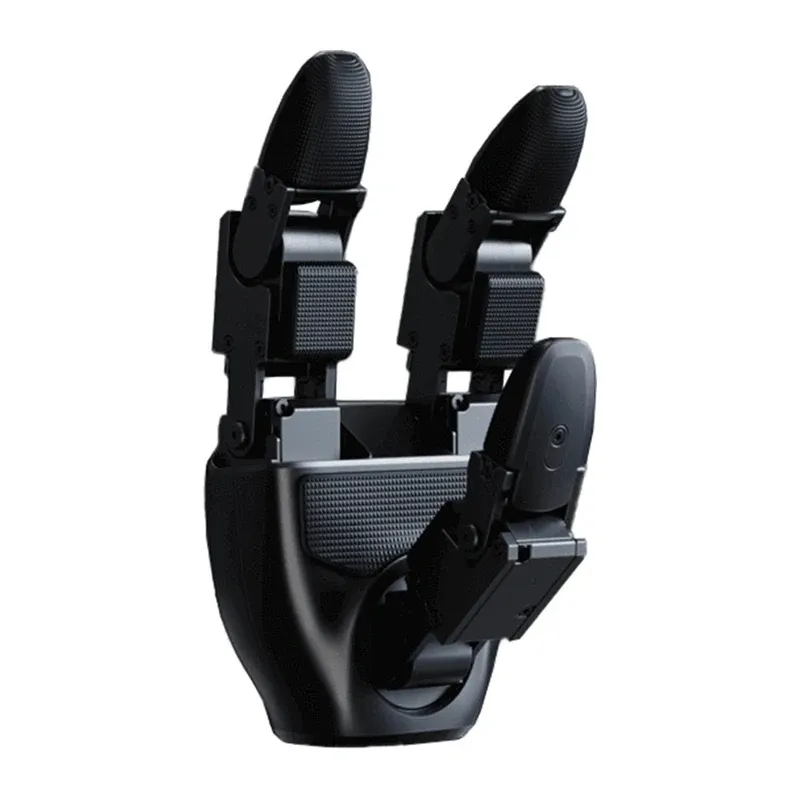
UNITREE G1 Dex3-1 Robotic Hands with Tactile Sensors
This set includes left and right three-fingered robotic hands designed for the UNITREE G1 humanoid robot. Each hand has 7 degrees of freedom, seven miniature brushless joints with force control, and 33 pressure sensors distributed across the palm, fingers and fingertips. Hybrid force and position control supports precise movement and object contact, with fingertip positioning repeatability of ±2 mm. Communication runs at 1,000 Hz via USB 2.0, providing detailed feedback on hand movement and contact.
7 degrees of freedom for precise movement
Each hand has three movable fingers: the thumb has 3 degrees of freedom, while the index and middle fingers each have 2. Joint ranges allow complex grip configurations. The thumb joints move through -60° to 60°, -35° to 60° and 0° to 100°. The index and middle finger joints each move through 0° to 90° and 0° to 100°. This arrangement supports movement across multiple planes and adaptation to different tasks. Fingertip positioning repeatability is ±2 mm.
33 pressure sensors for contact measurement
Each hand contains nine sensor arrays with 33 pressure sensors in total; the pair provides 66 measurement elements. Three 2 × 2 arrays are located on the palm, three 2 × 2 arrays on the fingers, and three 3 × 1 arrays at the fingertips. The detection range is 10–2,500 g, and the maximum load the sensors can withstand without damage is 20 kg. The sensors also report their temperature. A 1,000 Hz communication frequency supports rapid data acquisition for contact analysis and control.
Hybrid force control and advanced joints
Hybrid force and position control allows the hands to control more than just finger positions. Each hand has six miniature, directly driven brushless force-control joints and one geared joint. The F-1515-108 and F-1515-214 joint models support control of torque, angle, angular velocity, stiffness and damping. For the F-1515-108, theoretical maximum torque is 0.76 Nm; actual torque is 0.49 Nm in the direction of rotation and 1.37 Nm in the opposite direction. For the F-1515-214, the corresponding values are 1.498 Nm, 0.86 Nm and 3.1 Nm.
Real-time feedback data
The system reports mechanical and sensor status, including joint mode, position, velocity, torque and temperature, as well as voltage, current, sensor pressure, sensor temperature and IMU data. Control feedback also includes joint stiffness and damping coefficients. This information supports detailed monitoring during tasks and the use of multiple parameters in motion planning and control.
1,000 Hz communication and USB 2.0
The communication interface is USB 2.0, with a communication frequency of 1,000 Hz. A full data packet is 1,234 bytes for transmission and 1,270 bytes for reception. Joint control also operates at 1,000 Hz, and joint communication uses High Speed Unibus. These specifications support frequent control updates and access to detailed hand-status data during complex motion sequences.
Designed for the UNITREE G1
Each hand weighs 710 g and measures 175 × 88 × 77 mm when extended. Designed to work with the UNITREE G1 humanoid robot, the Dex3-1 combines a compact mechanism with an advanced motion system, pressure sensors and feedback functions for manipulation and measurement.
Specifications
General
- Manufacturer: UNITREE
- Model: DEX3WT-214T
- Compatibility: UNITREE G1
Hand specifications
- Weight: 710 g per hand
- Dimensions: 175 × 88 × 77 mm (extended)
- Degrees of freedom: Thumb ×3; index finger ×2; middle finger ×2
- Drive mechanism: 6 direct-drive motors; 1 gear-driven motor
- Joint range of motion: Thumb joint 0: -60° to 60°; thumb joint 1: -35° to 60°; thumb joint 2: 0° to 100°; index finger joint 0: 0° to 90°; index finger joint 1: 0° to 100°; middle finger joint 0: 0° to 90°; middle finger joint 1: 0° to 100°
- Fingertip positioning repeatability: ±2 mm
- Operating voltage: 12–58 V
- Standby current: 0.2 A at 58 V
- Maximum current: 10 A
- Communication interface: USB 2.0
- Operating temperature range: -20°C to 60°C
- Load conditions (palm facing down, room temperature, gripping a hard round object with a diameter of 5 cm): Maximum weight: 500 g; maximum power: 400 W for 3 s
- Load conditions (palm facing left, room temperature, gripping a hard round object with a diameter of 5 cm): Maximum weight: 500 g; maximum power: 400 W for 3 s
Sensor parameters
- Number of sensor arrays: 9 (33 pressure sensors per hand)
- Sensor array resolution: 2 × 2 (palm area) ×3; 2 × 2 (finger pad) ×3; 3 × 1 (single fingertip) ×3
- Detection range: 10–2,500 g
- Maximum load without damage: 20 kg
Software and communication
- Communication frequency: 1,000 Hz
- Full data packet size: Transmitter: 1,234 bytes; receiver: 1,270 bytes
- Measurement feedback data: Joint mode, joint position, joint speed, joint torque, joint temperature, voltage and current, sensor pressure value, sensor temperature and IMU data
- Control feedback: Joint mode, joint position, joint speed, joint torque, joint stiffness coefficient and joint damping coefficient
Miniature brushless force-controlled joints
- Models: F-1515-108 and F-1515-214 miniature brushless force-controlled joints
- Weight: 45 g
- Dimensions: 34.8 × 23.1 × 23.3 mm
- Gear ratio: F-1515-108: 1:108; F-1515-214: 1:214
- Maximum torque (theoretical): F-1515-108: 0.76 Nm; F-1515-214: 1.498 Nm
- Maximum torque (actual, in direction of rotation): F-1515-108: 0.49 Nm; F-1515-214: 0.86 Nm
- Maximum torque (actual, opposite to direction of rotation): F-1515-108: 1.37 Nm; F-1515-214: 3.1 Nm
- Maximum rotational speed: F-1515-108: 23 rad/s; F-1515-214: 11 rad/s
- Maximum line current: 4.76 A
- Control communication frequency: 1,000 Hz
- Communication method: High Speed Unibus
- Encoder: Absolute rotor position encoder
- Operating temperature range: -20°C to 60°C
- IP rating: Not specified
- Operating voltage: 12–24 V
- Motor feedback: Torque, angle, angular velocity and temperature
- Motor control commands: Torque, angle, angular velocity, stiffness and damping